Products
Purpose-built terminals for the hard cases — traffic, fire safety and facility inspection — raising the efficiency and the quality of public services on the ground.
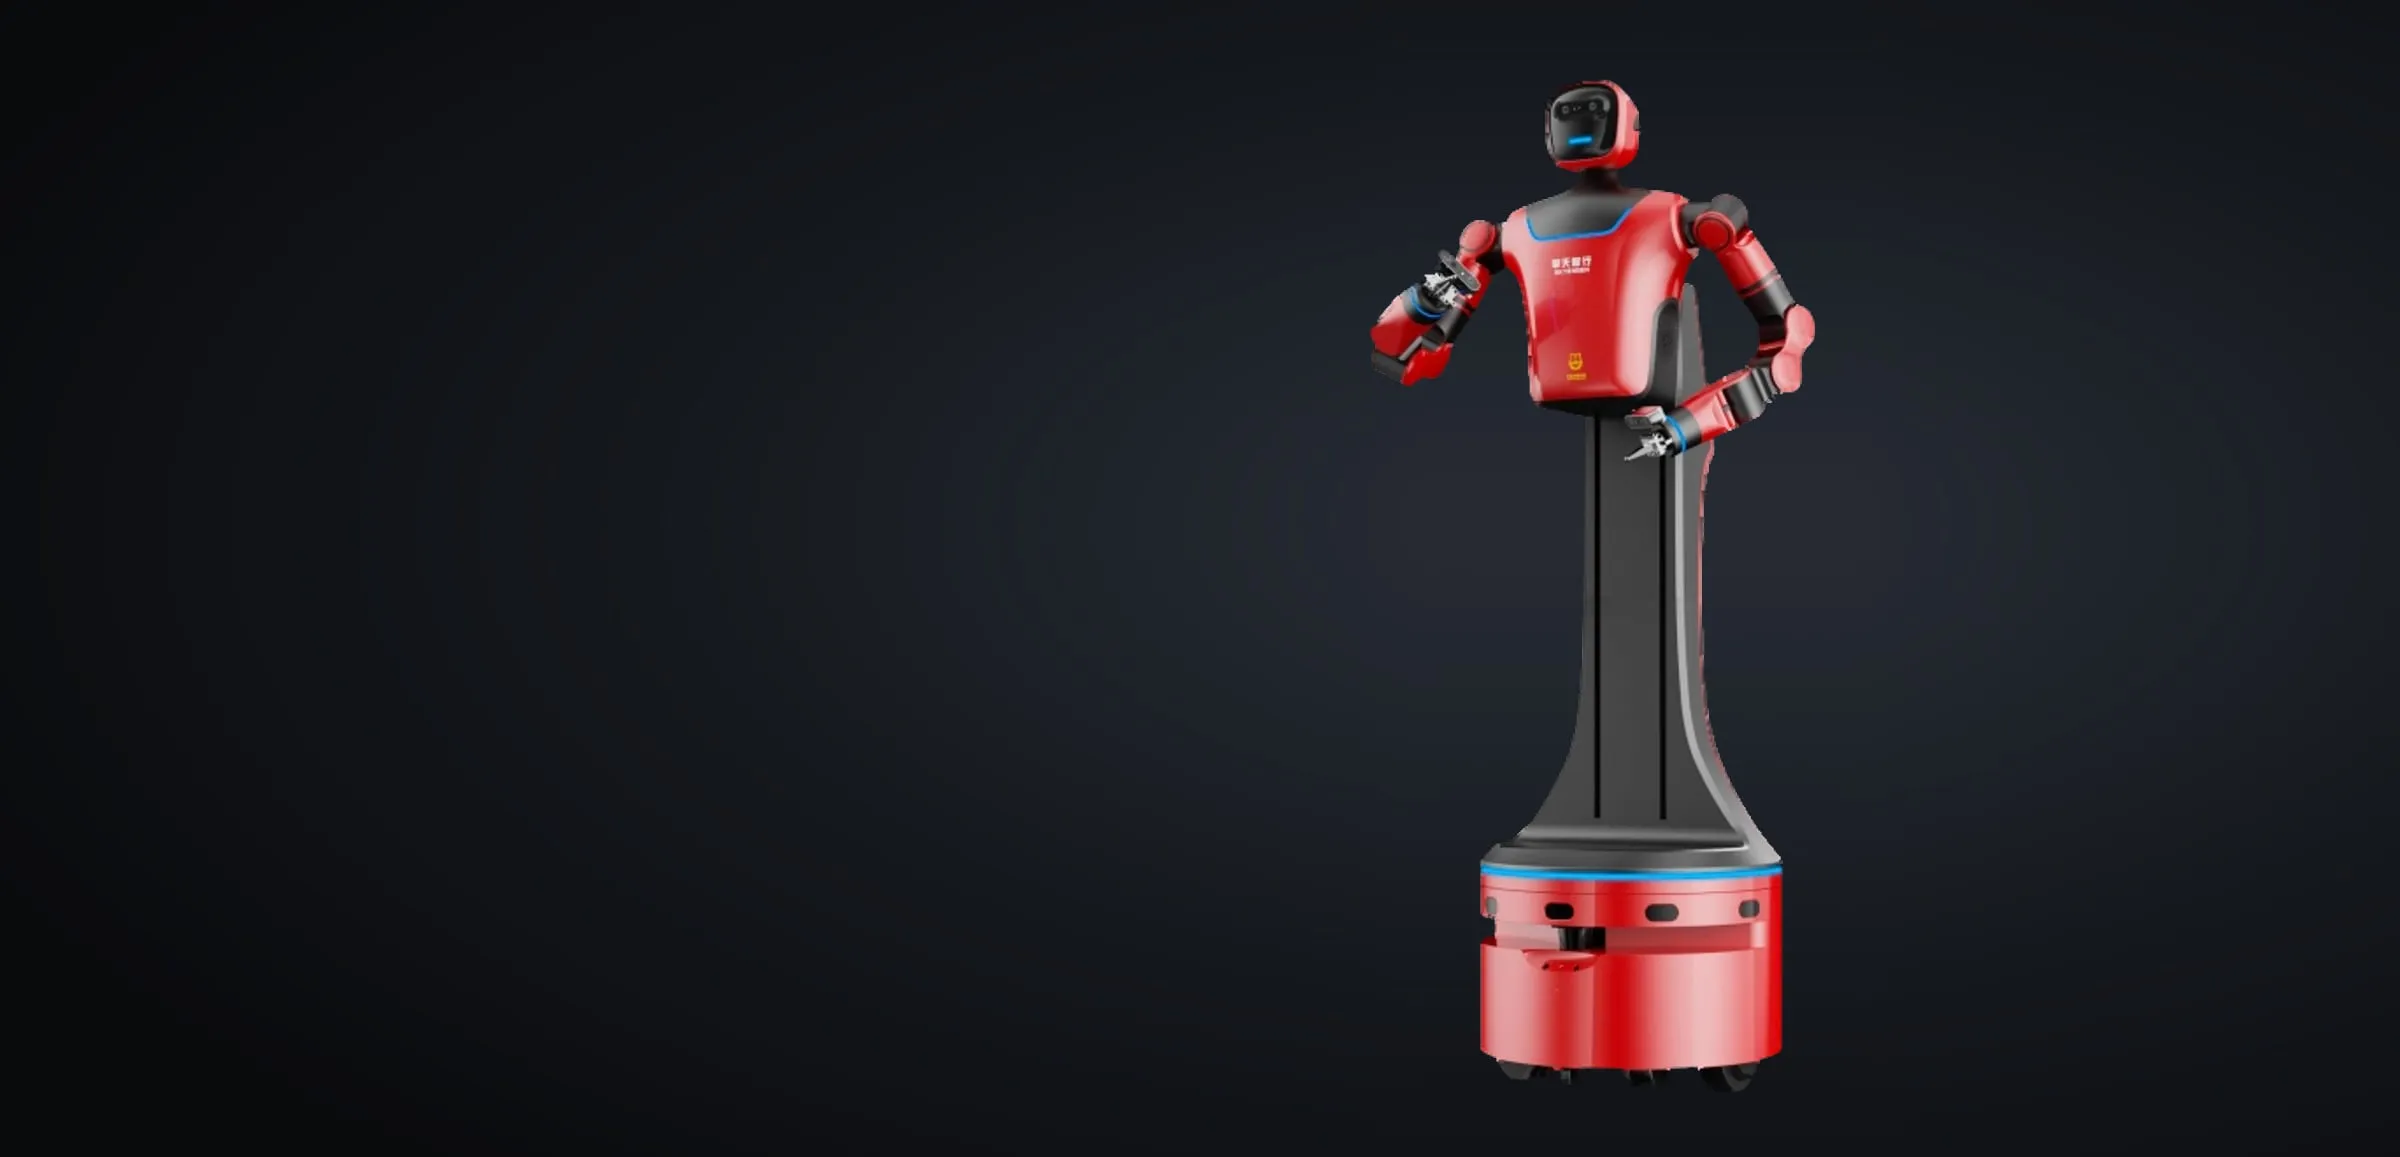
Fire Control Duty Robot
QTX100
Human–machine collaboration that cuts cost and lifts output
SpecificationsDetects fire conditions precisely around the clock and files the records automatically, matching human response times. Every action is logged, traceable and auditable to fire-inspection standards.
Core capabilities
Alarm detection
- Smoke, heat and manual call-point signals received in real time
- Alarms reported in 10 s, remote commands executed in 3 s
Fire response
- Full set of linked commands issued the moment an alarm is confirmed
- Coordinates with responders and keeps a complete record
False-alarm reset
- Resets and analyses automatically once a false alarm is confirmed
- Generates time-stamped electronic records
Data analysis
- Panel, video and vision data combined
- Supports second-stage confirmation and overall assessment
Logging and handover
- Checks and logs equipment status every 2 hours
- Records each shift change and flags open items
Power and network loss
- Cuts consumption and raises an alert on low battery
- Core functions keep running and no data is lost
Key metrics
- Fire-alarm response time
- ≤ 5 s
- AI false-alarm filtering
- ≥ 95%
- Residual false alarms ≤ 3%
- Button recognition
- ≥ 99%
- Manipulator accuracy
- ≥ 99%
- Measured as successful presses
- Docking accuracy
- ± 10 mm
- Electronic log completeness
- 100%
- Every 2 h, every event, every shift change
- System availability
- ≥ 99.5%
Specifications
| Robot | Working height | 400 to 1700 mm, every height reachable |
|---|---|---|
| Working radius | About 700 mm | |
| End-effector accuracy | ≤ ±1 mm, presses buttons as small as 5 × 5 mm | |
| Stowed size | Base ≤ 500 × 500 mm, stowed height ≤ 1400 mm | |
| Lift | Structure and stroke | Lifting column, effective stroke ≥ 700 mm |
| Drive and safety | DC servo + ball screw, fail-safe brake, limit protection | |
| Arm | Degrees of freedom | 6 |
| Reducer | Planetary gear reducer | |
| Payload and weight | Rated payload ≥ 1.5 kg, arm weight ≤ 12 kg | |
| Effector | Pressing tip | Soft tip, 3 mm diameter |
| Force control | Adjustable 5 to 20 N, jitter ≤ ±0.2 mm, retracts in ≤ 200 ms | |
| Chassis | Drive | Differential drive |
| Stability | Anti-tip safety factor ≥ 1.5, internal ballast lowers the centre of gravity | |
| Travel and navigation | Top speed ≥ 1.2 m/s, docking accuracy ± 10 mm | |
| Safety | 360° obstacle avoidance + bump strips + hardware emergency stop | |
| Battery | Lithium battery, ≥ 2 h runtime, automatic charging | |
| Housing | Ingress protection | IP44 |
| Panel joints | Tongue-and-groove joints + closed-cell EPDM seals | |
| Service | Modular design | Modules detach independently; replace one part without dismantling the robot |